By a Cartesian coordinate system in the plane we mean a rectangular system
(O,i,j), in which O is the origin and i i j are the unit vectors of the two
axes, of the abscissa and of the ordinate respectively; a plane carrying a
Cartesian system is called a Cartesian plane. The set {i,j} is a basis
of the set of vectors in the plane. In such a system, a vector OM is
expressed uniquely in the form
OM=xi+yj,x,y∈R
Segments
The distance between two points A(x1,y1),B(x2,y2):
AB=(x2−x1)2+(y2−y1)2;
The distance between the points M1(x1,y1,z1) and M2(x2,y2,z2) in space is M1M2=(x1−x2)2+(y1−y2)2+(z1−z2)2.
The gradient of the line AB:mAB=x2−x1y2−y1;
The coordinates of the point M(x,y), the midpoint of the segment AB;
;
x=2x1+x2,y=2y1+y2
The coordinates of the point M dividing the segment (AB) in the ratio
k:
x=1+kx1+kx2,y=1+ky1+ky2
The equation of a line.
Lines parallel to the coordinate axes:
(d):x=a(d∣∣Oy),(d):y=a(d∣∣Ox);
The line determined by the point M0(x0,y0) and the non-zero vector aˉ(u,v):(d):rˉ=rˉ0+taˉ,t∈R,
rˉ0 – the position vector M of the line d;
(d):{x=x0+uty=y0+vt,t∈R, the parametric equations;
The explicit equation: y=mx+n, m∈R∗,n∈R,m – the gradient, n – the
y-intercept;
The intercept equation: ax+by−1=0,(a,b∈R∗), where the points A(a,0) and B(0,b) are
the intercepts;
The equation of the line of gradient m through the point M(x0,y0):
The general equation of a plane in three-dimensional space is Ax+By+Cz+D=0, where
A,B,C are not all zero. The position vector with coordinates (A,B,C) is
perpendicular to the plane Ax+By+Cz+D=0.
The equation of the plane through the point (x0,y0,z0) is:
A(x−x0)+B(y−y0)+C(z−z0)=0.
The equation of the plane through 3 non-collinear points (x1,y1,z1), (x2,y2,z2),
(x3,y3,z3) is xx1x2x3yy1y2y3zz1z2z31111=0. The condition for three points with coordinates (x1,y1,z1),
(x2,y2,z2), (x3,y3,z3) to be non-collinear is .
Two planes p:Ax+By+Cz+D=0 and p′:A′x+B′y+C′z+D′=0 with A′A=B′B or B′B=C′C or A′A=C′C intersect in a
line.
Equations of a line in space
The parametric equations of the line determined by the point M0(x0,y0,z0) and the
direction vector v(l,m,n) are d:⎩⎨⎧x=x0+λ⋅ly=y0+λ⋅mz=z0+λ⋅n, where λ∈R.
The line determined by the point M0(x0,y0,z0) and the direction vector v(l,m,n) can be
described by the canonical equations: lx−x0=my−y0=nz−z0.
Let M1(x1,y1,z1), M2(x2,y2,z2) be points of the line d. Then the canonical equations of
the line d:x2−x1x−x1=y2−y1y−y1=z2−z1z−z1, x1=x2, y1=y2, z1=z2.
Let the lines d1 and d2 be given by the canonical equations l1x−x1=m1y−y1=n1z−z1
and l2x−x2=m2y−y2=n2z−z2 respectively. The angle φ formed by the lines d1 and
d2 is given by the formula: cosφ=±l12+m12+n12⋅l22+m22+n22l1⋅l2+m1⋅m2+n1⋅n2.
The relative position of a line and a plane
Let d:lx−x0=my−y0=nz−z0 and the plane: Ax+By+Cz+D=0.
If Al+Bm+Cn=0, d meets the plane in a point.
If Al+Bm+Cn=0 and Ax0+By0+Cz0+d=0, then d∣∣??
If Al+Bm+Cn=0 and Ax0+By0+Cz0+d=0, then d⊂??.
The angle between a line and a plane
Let the line d be given by the equations lx−x0=my−y0=nz−z0 and the plane by the equation
Ax+By+Cz+D=0. Let φ be the angle between the line d and the plane.
We have: sinφ=l2+m2+n2⋅A2+B2+C2∣A⋅l+B⋅m+C⋅n∣.
The distance from a pointM(x0,y0,z0)to a plane is:
d=A2+B2+C2∣Ax0+By0+Cz0+D∣, if the equation of the plane is Ax+By+Cz+D=0.
The planes with equations A1x+B1y+C1z+D=0 and A2x+B2y+C2z+D=0 have the cosine of the angle
between them given by the formula:
The planes :A1x+B1y+C1z+D1=0 and :A2x+B2y+C2z+D2=0 are parallel if A2A1=B2B1=C2C1=D2D1 (A1 and A2,
B1 and B2, or C1 and C2 respectively may be simultaneously
zero).
The area of the triangle with verticesM1(x1,y1,z1), M2(x2,y2,z2), M3(x3,y3,z3) is:
A[M1M2M3]=21Δ12+Δ22+Δ32, with Δ1=y1y2y3z1z2z3111, Δ2=x1x2x3z1z2z3111,
Δ3=x1x2x3y1y2y3111
* The volume of the tetrahedron with vertices M0(x0,y0,z0), M1(x1,y1,z1), M2(x2,y2,z2),
M3(x3,y3,z3) is
V=61∣x0x1x2x3y0y1y2y3z0z1z2z31111∣ (61 of the absolute value of the determinant).
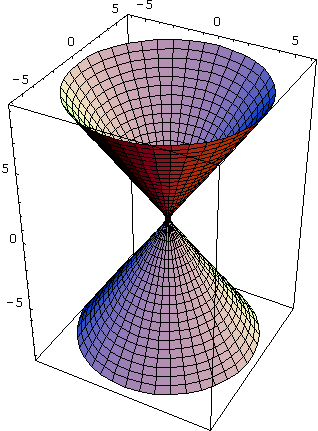
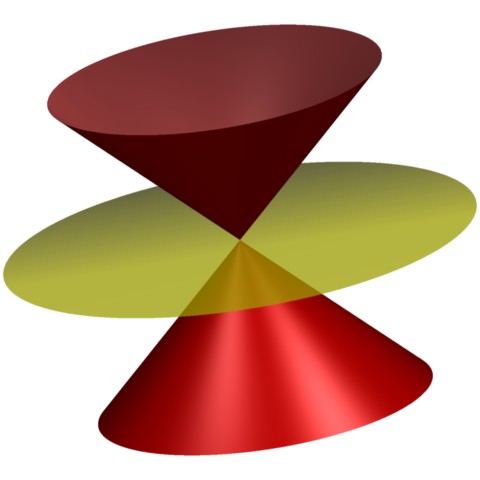
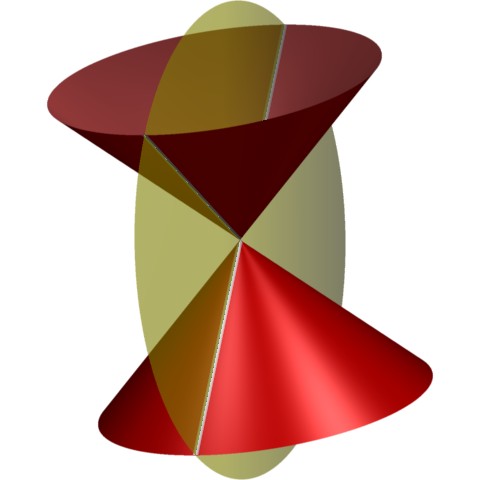
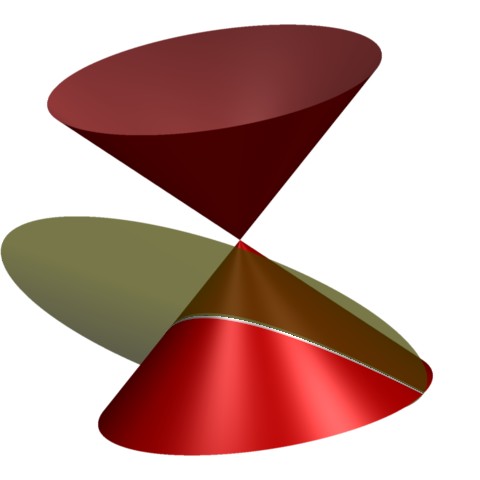
In a double cone of revolution whose height is h→∞, the cross-sections are
called conics, and they may be: a point, two intersecting lines, a circle, an
ellipse, a hyperbola or a parabola, as follows:
first, the double cone uncut
the cutting plane passes through the apex and meets neither nappe of the cone
the cutting plane passes through the apex and meets the nappes of the cone
the cutting plane meets only one nappe of the cone and cuts every generator
the cutting plane meets both nappes of the cone
the cutting plane meets only one nappe of the cone and is parallel to a
generator
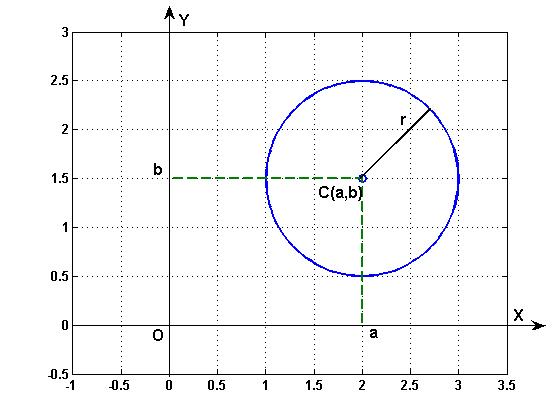
1. The circle
Equation of the circle: (x−a)2+(y−b)2=r2;
if M(a,b)=O(0,0):x2+y2=r2;
Normal equation:x2+y2+mx+ny+p=0, where a=−2m, b=−2n and r2=41(m2+n2)−p.
The parametric equations are:x(θ)=a+rcos(θ)y(θ)=b+rsin(θ);θ∈[0,2π].
x(t)=1+t21−t2;y(t)=1+t22t
Equation of the tangent at the pointM(x0,y0),M∈cercului; xx0+yy0−r2=0
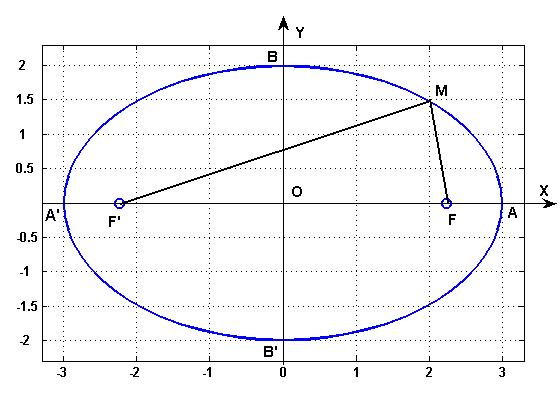
1. The ellipse E: F(c,0),F′(−c,0),A(a,0),A′(−a,0),B(0,b),B′(0,−b),
Equation of the ellipse:a2x2+b2y2−1=0,b2+c2=a2
Equation of the tangent at the pointM(x0,y0),M∈E; a2xx0+b2yy0−1=0
The parametric equations are: x(θ)=acos(θ)y(θ)=bsin(θ);θ∈[0,2π].
The ellipse is the orthogonal projection of the circle centred at the origin of
radius r=a, lying in a plane making with the plane of the ellipse the angle
α given by the relation cos(α)=ab.
The ellipse is the locus of the points for which the sum of the distances to two
fixed points, called foci, is constant. MF+MF′=2a,M∈E;
The eccentricity of the ellipse is: e=ac<1.
The area of the ellipse is: S=πab.
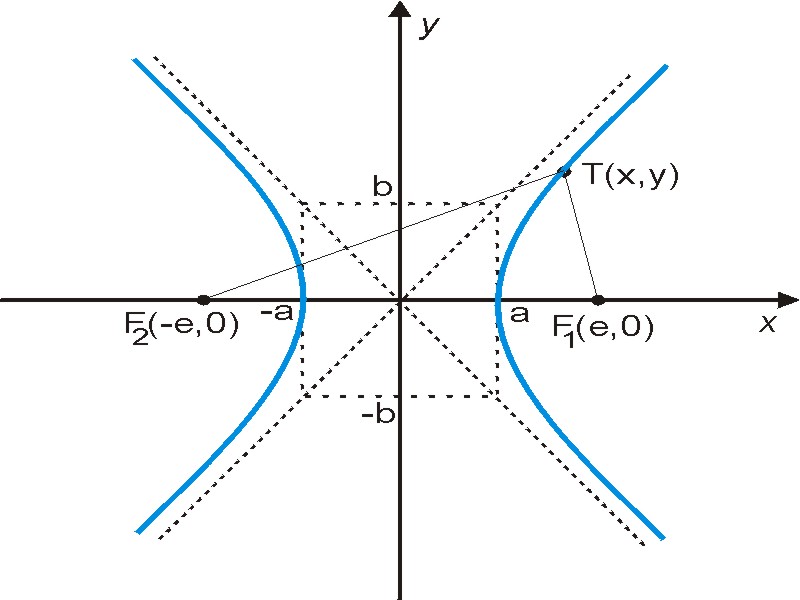
2. The hyperbola H: a2x2−b2y2−1=0,c2−b2=a2
∣TF−TF′∣=2a,M∈H;
Equation of the hyperbola:a2x2−b2y2−1=0,c2=a2+b2;
Equation of the tangent at M0(x0,y0),M0∈H: a2xx0−b2yy0−1=0
The hyperbola with centre A(p,q), referred to the system xOy, has the equation:
a2(x−p)2−b2(y−q)2−1=0.
The parametric equations are: x(t)=2a(t+t1),y(t)=2b(t−t1);t∈R
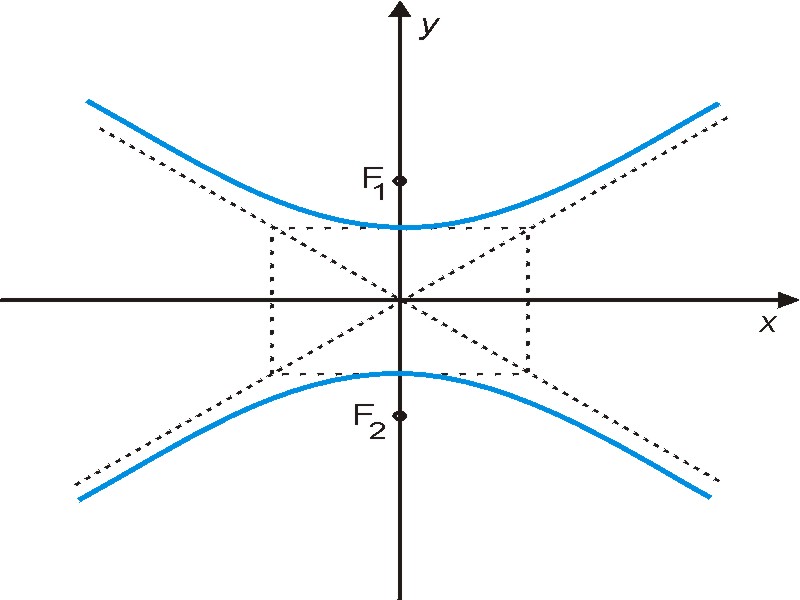
Equation of the conjugate hyperbola: a2x2−b2y2+1=0,c2=a2+b2;
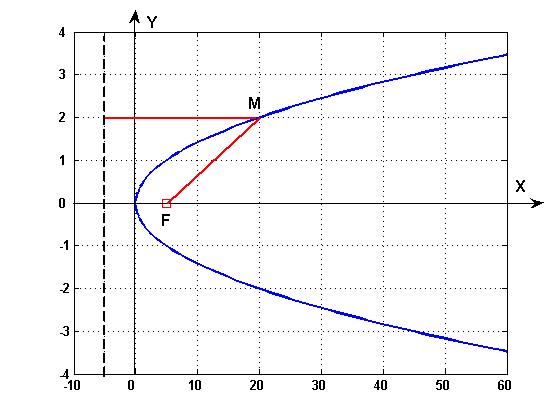
3. The parabola P: F(2P,0),h:x=−2P (h – the directrix): d(M,h)=MF,M∈P;
Equation of the parabola: y2=2px;
Equation of the tangent at M0(x0,y0),M0∈P: yy0=p(x+x0).
The parametric equations are: x(t)=2pt2,y(t)=t;t∈R
Tangent to a conic from a point P outside the conic
The equation of a line through P(xp,yp) with gradient m is y−yp=m(x−xp). Intersect
this line with the conic, that is, write the system formed by their equations:
{y−yp=m(x−xp)′′ecuaiaconicei′′
Solve the system and impose the condition that the tangent meets the conic in a
single point (Δ=0).
Intersection of two conics, or of a conic and a line
The intersections are found by solving the system formed from the equations of
the two conics. The resulting solution gives the points of intersection.


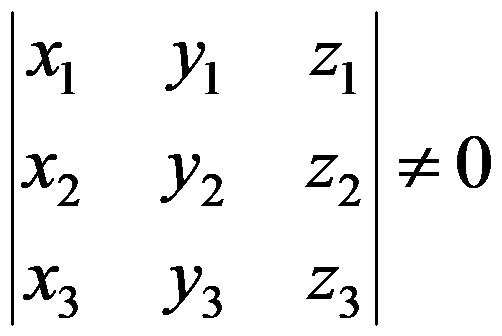 .